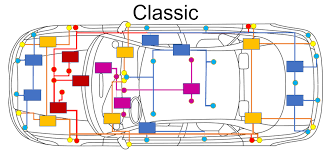
Higher levels of vehicle autonomy require unprecedented data throughput from diverse perception sensors operating continuously across the vehicle frame. Advanced Level 3 and Level 4 autonomous systems rely on combined streams from optical cameras, millimeter-wave radar, LiDAR scanners, and ultrasonic transceivers to build a continuous, high-resolution spatial model of the driving environment. Raw data feeds from multiple high-definition vision sensors require multi-gigabit streaming capacities to central perception engines with near-zero latency, as any processing delay degrades obstacle detection and collision avoidance capabilities. Consequently, automotive network engineers must abandon traditional point-to-point sensor wiring in favor of scalable serialized links, high-speed Ethernet backbones, and uncompressed video transport protocols capable of delivering gigabits of raw data per second across flexible, lightweight physical media.
Meeting autonomous driving data requirements requires optimizing physical network topology, processing locations, and system redundancy. Automotive systems designers weigh the benefits of edge processing—where raw sensor data is filtered locally before transmission—against centralized raw sensor fusion, which provides higher perception accuracy but demands substantially higher network bandwidth. Furthermore, functional safety standards require full physical and logical network redundancy for critical autonomous channels. Dual-homed network pathways, redundant Ethernet switches, and parallel power distribution loops ensure that a single wire fault, connector failure, or transceiver breakdown cannot blind perception software or disrupt control loops. By leveraging data from In-Vehicle Networking Market research, vehicle development teams design fault-operational networking structures that maintain continuous situational awareness and execute safe stop maneuvers under all potential failure conditions.
What is the difference between edge-processed sensor fusion and centralized raw sensor fusion? In edge processing, sensors use local microprocessors to process raw data and transmit smaller summary packets (such as object coordinates) over low-bandwidth networks. In centralized raw sensor fusion, unprocessed camera, radar, and LiDAR data streams directly to a central supercomputer over high-speed Ethernet or SerDes links. Centralized fusion provides better perception accuracy by preserving all raw data, but requires high network bandwidth and central compute capacity.
Why is network redundancy necessary for Level 3 and higher autonomous driving? Level 3 and higher autonomous systems allow the driver to disengage from active vehicle operation, placing full operational responsibility on the vehicle software. If a primary network line or switch fails, the autonomous system must continue functioning seamlessly. Redundant physical network pathways, redundant switches, and fail-operational protocols ensure control commands and sensor feeds remain active so the vehicle can operate safely or perform an emergency stop.
➤➤➤Explore MRFR’s Related Ongoing Coverage In Semiconductor Industry:
Digital Transformation In Bfsi Market
Directors And Officers Insurance Market